DexRefineRGB-guided, contact-aware robot reference refinement
Dexterous Manipulation · Human-to-Robot Retargeting · Contact Guidance · Physics Optimization
DexRefine turns noisy human hand–object demonstrations into physically plausible robot references using RGB contact guidance, grasp-locked correction, Wuji retargeting, collision-aware refinement, and SPIDER/MJWP physics rollouts.
Best Project · Learning for Robotics · VLMs · Robot Tool Use
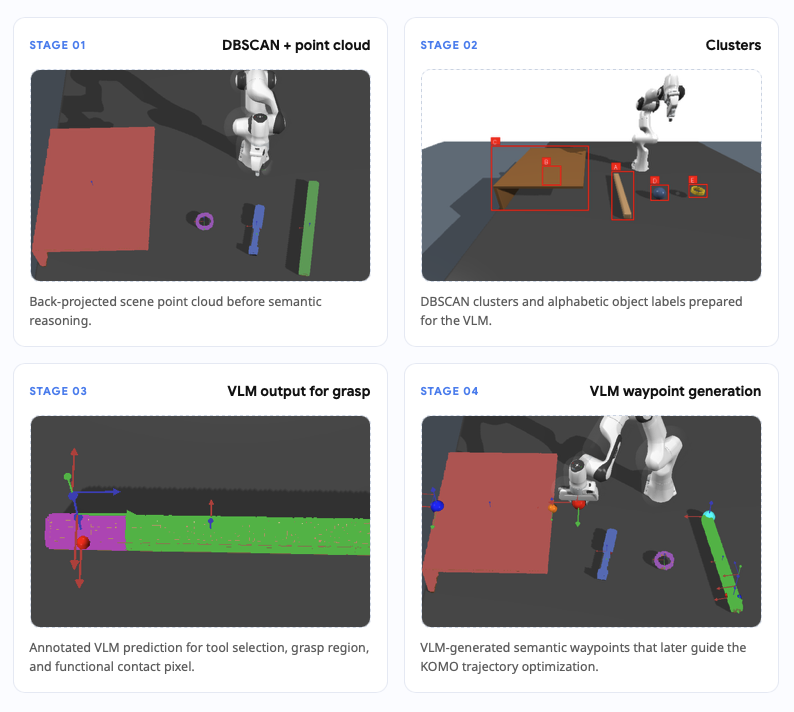
We developed a structured VLM Chain-of-Thought method for geometry analysis, grasp localization, and contact-tip localization, followed by depth refinement and KOMO motion planning. Selected as the Best Project in Bilkent University's Learning for Robotics course.
PPO-MAML for Meta-World Assembly-v3
Reinforcement Learning · Meta-RL · Robotic Manipulation
A compact PyTorch implementation combining Model-Agnostic Meta-Learning (MAML) with a PPO inner loop on the Meta-World ML1 assembly-v3 benchmark, targeting fast policy adaptation for a robotic arm under task variations. A single ~200-line script with fixed seeds, CSV logging, and GIF rollouts.
Domain-Invariant Racer
Reinforcement Learning · Domain Randomization · Sim-to-Real
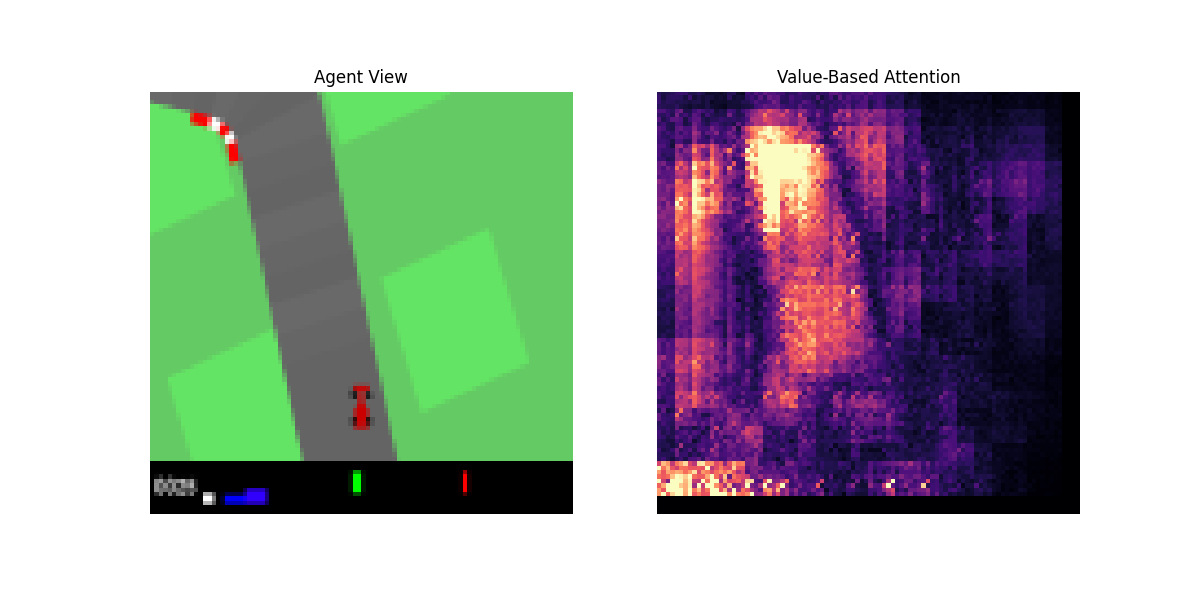
A PPO-based racing agent trained under heavy visual and physics randomization, learning domain-invariant representations that stay stable under changing textures, lighting, and noise. Focused on robustness analysis and attention visualization.
Safe Swarm Control with HOCBFs
Multi-Agent Systems · Control · Control Barrier Functions
Safety-critical control for multi-agent systems using High-Order Control Barrier Functions (HOCBFs), comparing centralized safety filtering for double-integrator dynamics against decentralized, distributed CBF formulations (solved with CVXPY) for collision avoidance with minimal control modification.
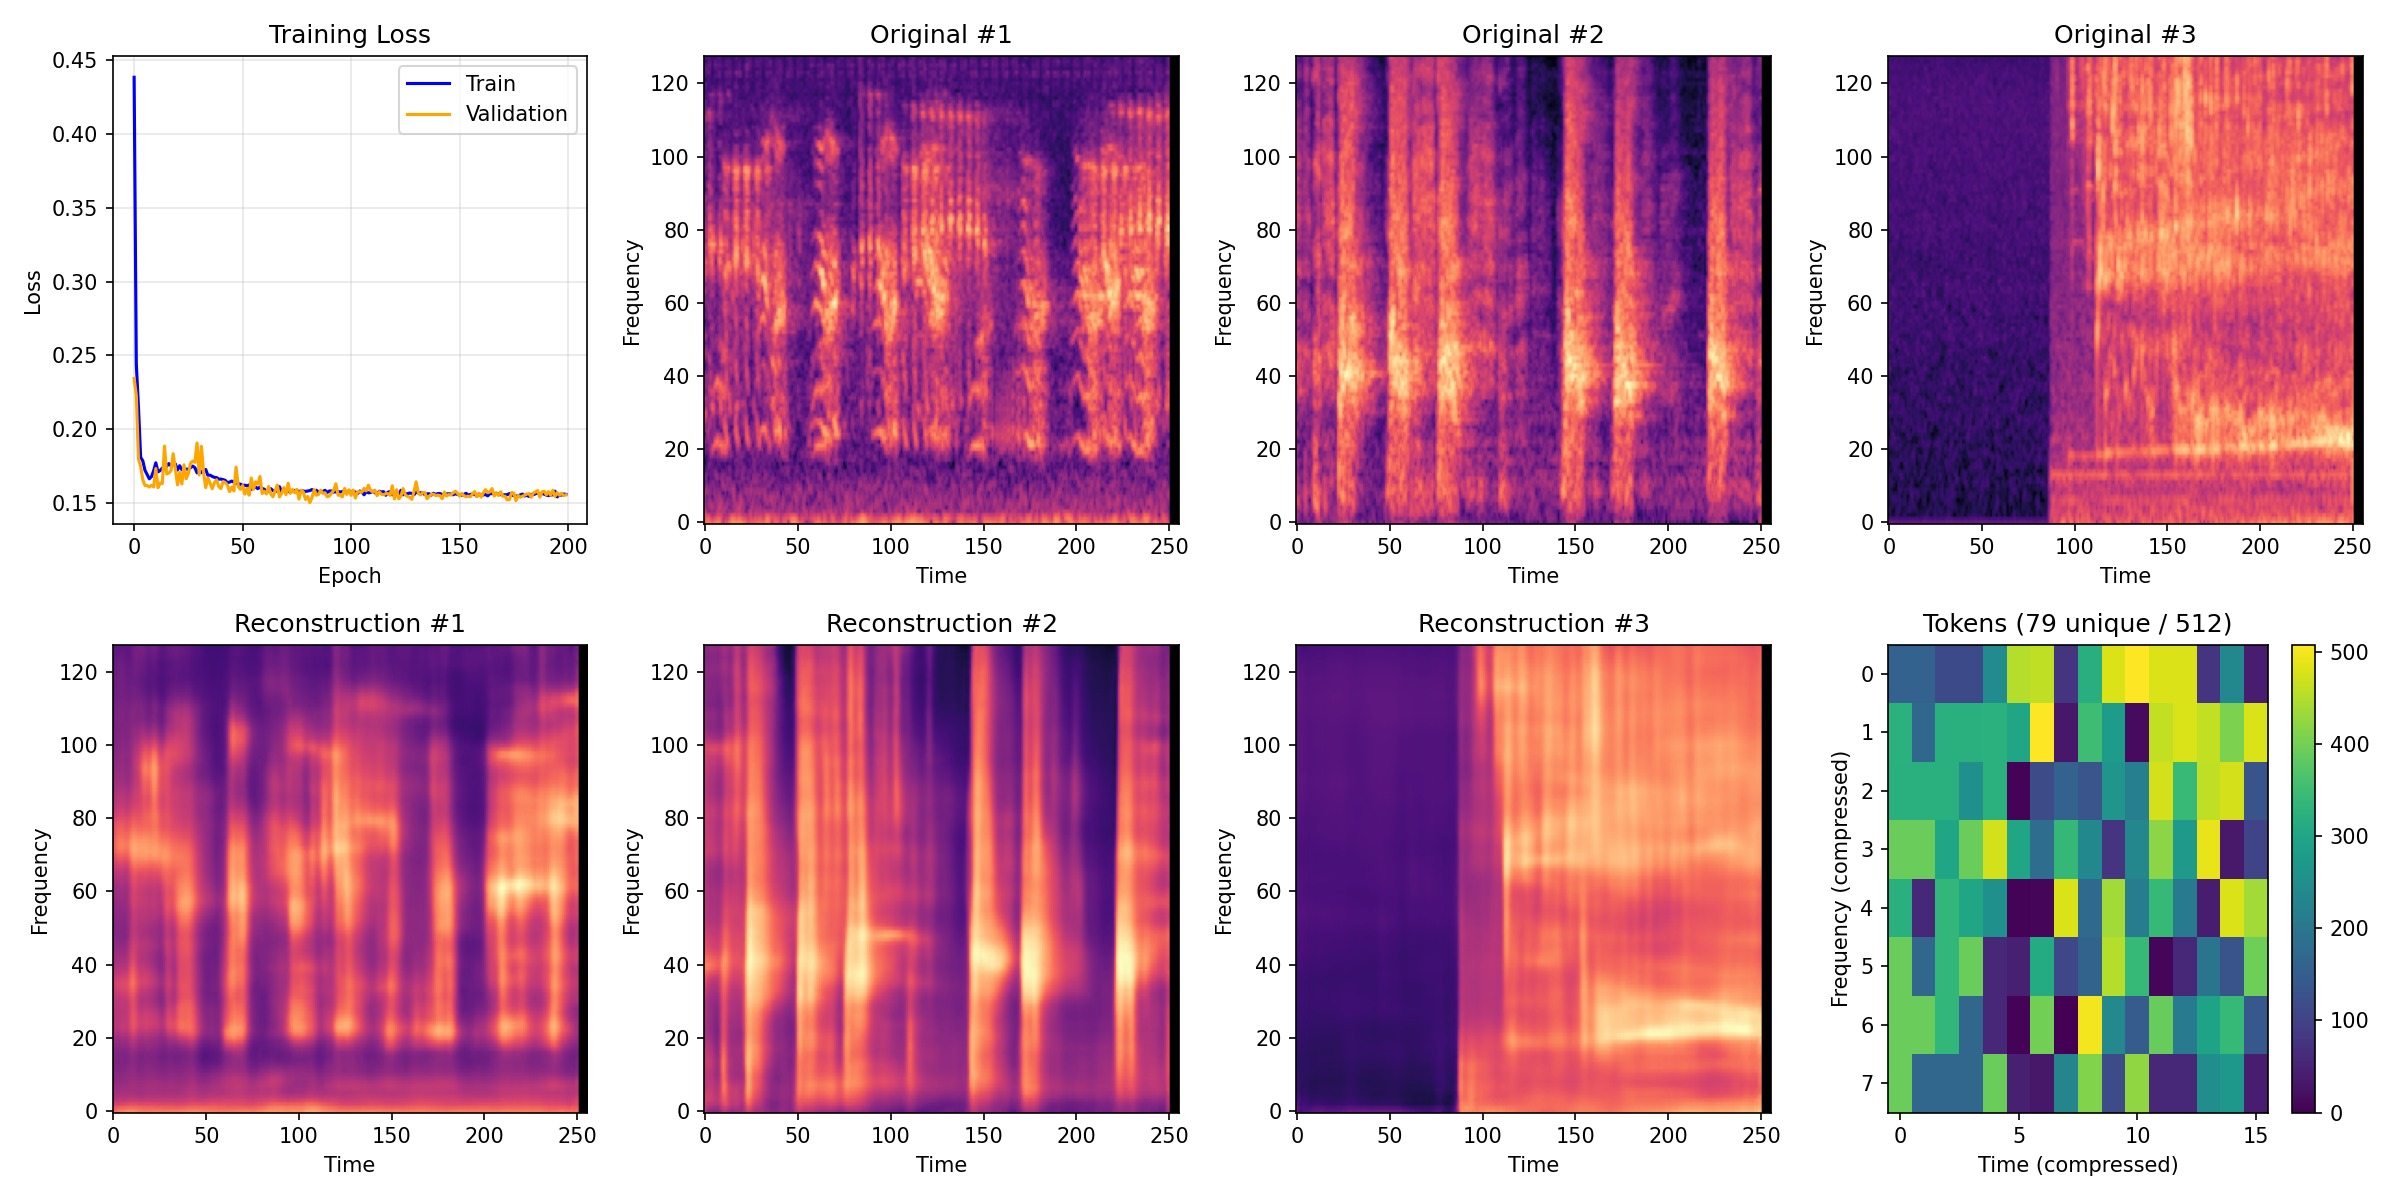
Multimodal Audio Tokenizer
Audio Representation Learning · Tokenization · Multimodal ML
A research-oriented project converting raw audio into compact, discrete token representations for multimodal learning. Designed as a modular pipeline so audio tokens can plug into transformers, multimodal encoders, or generative models alongside text or vision tokens.
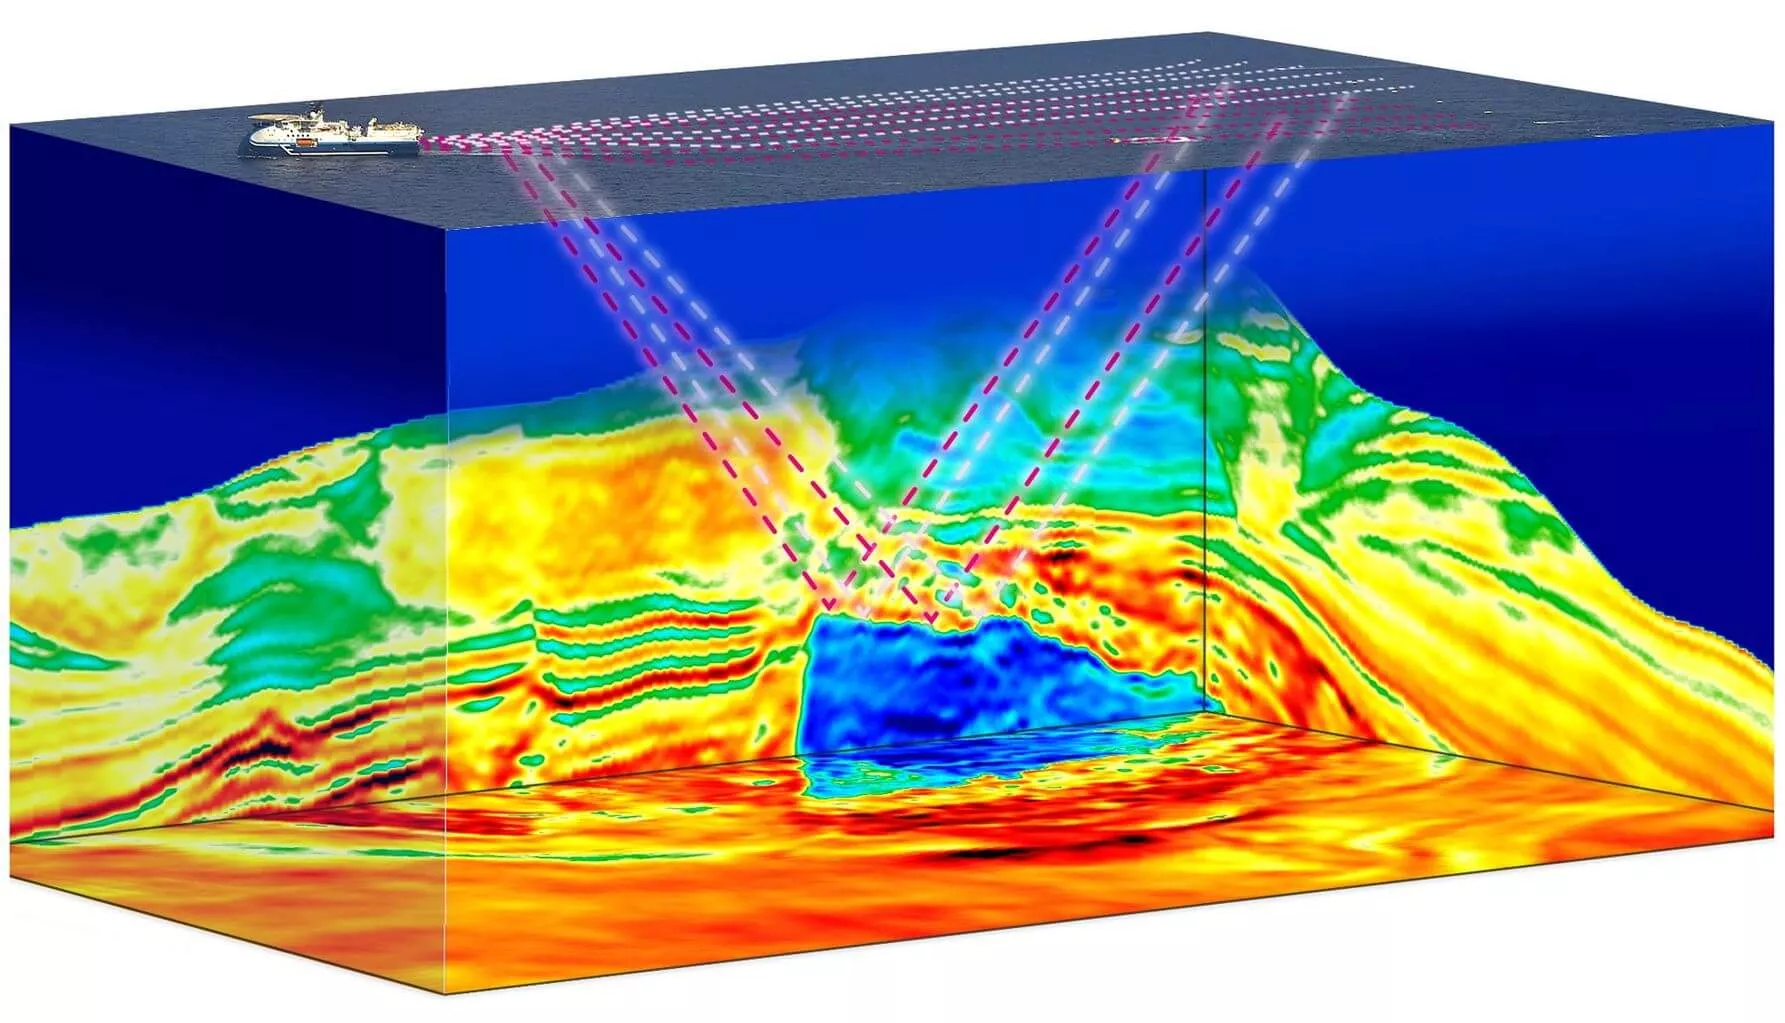
NeRF-inspired Seismic Subsurface Imaging
Neural Rendering · Seismic Imaging
Transferring Neural Radiance Fields ideas from multi-view camera rendering to marine seismic acquisition, treating offset and azimuth as view parameters. Also experiments with tokenizing seismic traces via time–frequency features and vector quantization for CMP-level structure with transformer models.
Image Super-Resolution with SwinIR
Image Restoration · Swin Transformer
Implemented and trained SwinIR for single-image super-resolution. Trained on LSDIR and evaluated on Manga109 (×2), reaching ~36.18 dB PSNR and outperforming a CNN baseline (RCAN).