Hi, I'm Talha — an EEE student at Bilkent University working at the intersection of robot learning, computer vision, and optimization. I'm interested in how robots can perceive 3D scenes, reason about objects and tools, and plan meaningful physical actions in the real world.
Most of my work focuses on dexterous robotic manipulation, world models, and grounding visual predictions in physical interaction through contact inference and real-robot rollouts. Right now I'm doing research on affordance-guided world models for dexterous manipulation at NYU CILVR with Lerrel Pinto, and contributing to CVXPY at Stanford on disciplined nonlinear programming.
I've studied as a visiting student at UC Berkeley and Stanford, taking courses in machine learning, convex optimization, information devices and systems, and technology leadership. Outside of coursework, I like building projects that tie together perception, planning, and control — with the long-term goal of making robotic systems more capable and reliable.
Selected projects
All projects
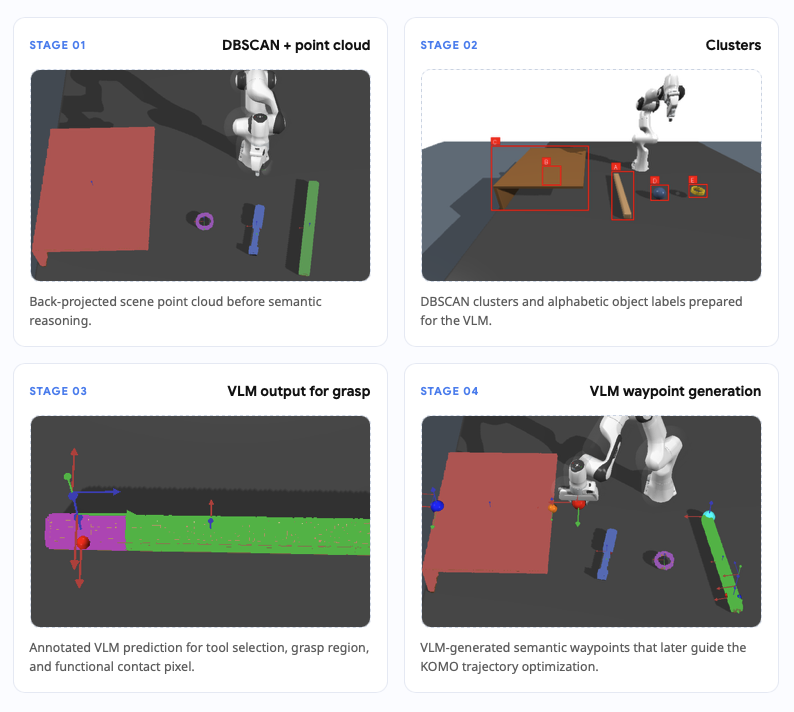
ToolMindVLM-guided spatial reasoning for robotic tool use
Best Project · Bilkent Learning for Robotics
Research experience

UG Research Intern — Robotics, NYU CILVR

DNLP Contributor — Stanford CVXPY
Education

Bilkent University
B.E. in Electrical & Electronics Engineering; robotics, machine learning, optimization, and signal processing.

UC Berkeley
Visiting student in EECS; information devices, systems foundations, and technology leadership.

Stanford University
Visiting student in CS; optimization, machine learning, and reinforcement learning.
Industry & teaching

Havelsan

SDT — ODTÜ Teknokent

Study Session Instructor, Stanford University
Beyond research
A few things that stay with me outside the lab: films, books, and music. I also keep a page for ideas I'm thinking about.
For research, collaboration, or just to say hello, get in touch.